

MoSense Raises RMB 100M to Build Robot Electronic Skin
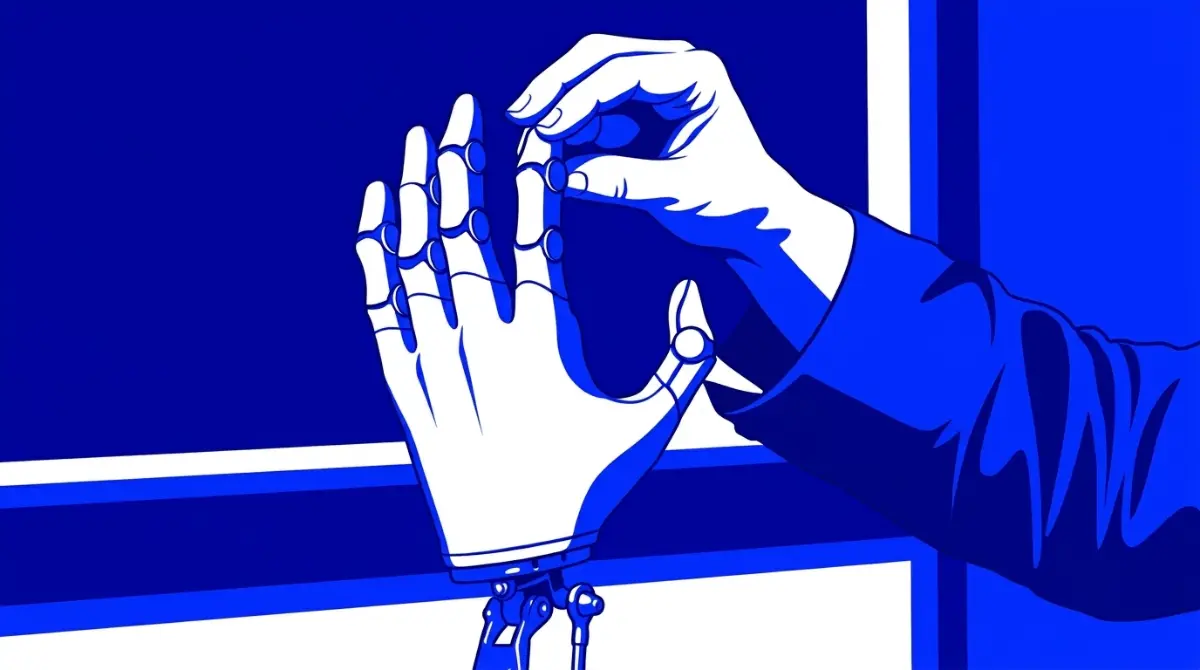
Shanghai robotics venture MoSense secured approximately one hundred million yuan in Angel-plus financing led by CDH Investments and Oasis Capital, developing three-dimensional electronic skin and tactile foundation models that give humanoid robots human-like touch perception across curved mechanical surfaces.
Umar Abubakar | · 8 min read
Humanoid robots have mastered sight, but remain completely numb to physical touch. A modern bipedal robot uses optical cameras and depth sensors to map surrounding rooms, identifying doorways, stairs, and obstacles with high accuracy. The moment a mechanical hand attempts to pick up a fragile raw egg, grasp an oily steel wrench, or lean against an unfamiliar surface, vision fails to provide the required feedback. Cameras cannot measure contact pressure, detect sliding friction, or feel mechanical vibrations along metal fingers. Human beings navigate physical environments because our skin contains millions of tactile mechanoreceptors that send millisecond neural signals to our brains, allowing us to adjust grip force instinctively. Shanghai robotics pioneer MoSense arrived to supply that missing sensory layer. Chinese business media reported on Tuesday, October 27, 2026, that MoSense secured an Angel-plus financing round of approximately one hundred million yuan, equal to roughly $14M. The investment was led by CDH Investments and Oasis Capital, joined by commercial robotics developers including LimX Dynamics and Agibot. The capital funds the development of full-body electronic skin and tactile foundation models, turning numb mechanical shells into touch-sensitive machines. The funding arrives as robotics ventures pursue sensory hardware, continuing deeptech investments we tracked when Sequoia backed Mecka AI for robot training data.
The investment round marks an important validation for founder Yan Zhaoxu and the core engineering team, who spun the venture out of research laboratories at the Hong Kong University of Science and Technology. The round included strategic follow-on commitments from domestic chipmakers and state-backed funds, including Loongson Venture Capital, CAS Star, Hua Capital, Pudong Venture Capital Group, and WestSummit Capital. MoSense established a competitive advantage by rejecting the traditional approach of treating electronic skin as a passive flexible sticker. Most sensor manufacturers produce flat sensory films that must be glued onto robot parts, peeling off curved joints after repeated motion. MoSense developed a full-stack architecture encompassing MoSkin hardware, MoTact signal processing algorithms, and MoWorld tactile world motion models. By integrating tactile sensors directly into the structural components of humanoid robots using advanced 3D printing techniques, MoSense enables machines to perceive touch across curved shoulders, waists, and fingertips without adding mechanical bulk. Early-stage robotics investments were detailed in our review of DeepSeek backing robotics startup Winverse.
The Structural Flaw of Traditional Flexible Films
To grasp why leading humanoid robot manufacturers are partnering with MoSense, one must examine the physical limitations of legacy electronic skins. Over the past decade, academic researchers developed dozens of electronic skins made from conductive fabrics, silicone elastomers, or flexible printed circuit films.
These traditional skins work well on flat testing surfaces inside university laboratories. When applied to real humanoid robots, they fail rapidly. A humanoid robot contains complex curved mechanical surfaces: rounded shoulder caps, contoured waist joints, and multi-axis spherical finger joints. Sticking a flat film onto a three-dimensional curved surface creates wrinkles, air pockets, and mechanical stress concentrations. As the robot moves, repetitive joint rotations stretch the sensory film, causing electrical wiring traces to crack and peel away from the structural chassis. Furthermore, gluing separate sensor layers onto an existing robot shell increases total component thickness and weight, altering motor dynamics and reducing battery runtimes. Yan Zhaoxu recognized that tactile sensing could not remain an afterthought glued to the outside of a machine; it had to become an integral physical part of the robot structural skeleton. Robotic precision manufacturing workflows were analyzed in our report on CloudNC automating precision factory operations.
Magneto-Photocuring 3D Printing and MoSkin Integration
The technical breakthrough that sets MoSense apart sits in advanced material fabrication: specifically magneto-photocuring 3D printing. Rather than manufacturing sensors and robot body shells separately, MoSense prints them as a unified component.
During the printing process, specialized photopolymer resins are infused with magnetic micro-particles and conductive nanoparticles. By applying magnetic fields while curing the resin with targeted ultraviolet light, engineers align the conductive particles into precise three-dimensional sensor arrays directly inside the structural shell wall. The resulting component acts as both the physical protective armor of the robot and a high-resolution tactile sensor. The technique allows MoSense to program mechanical properties on demand: tuning the outer shell to be rock-hard on protective shins, semi-rigid on forearms, or soft and compliant on fingertip pads, while maintaining uniform tactile sensitivity across all areas. Because the sensors are embedded inside the material itself, there are no exterior films to peel off, and no wiring harnesses to snag on mechanical joints. Hardware design choices across automated consumer machines were explored in our analysis of Dyson intelligent cleaning robots.
Comparing Humanoid Robot Perception Modalities
| Perception Modality | Primary Sensory Input | Environmental Blind Spot | Response Latency Profile | Physical Durability Level |
|---|---|---|---|---|
| MoSense Full-Body MoSkin | Normal force, shear friction, vibration | Distant non-contact obstacles | Sub-millisecond direct signal | High: embedded in 3D structure |
| Stereoscopic Optical Cameras | RGB visual pixels & depth arrays | Occluded contact zones under hands | 30 to 60 milliseconds processing | Delicate glass lenses scratch |
| Joint Torque Actuators | Motor electrical current resistance | Light contact force on fingers | 5 to 15 milliseconds mechanical delay | High: internal gearbox sensors |
| Traditional Adhesive Film Skin | Piezoresistive sheet voltage drops | Curved multi-axis joints | 1 to 5 milliseconds response | Poor: peels & tears under wear |
| Ultrasonic Proximity Arrays | Acoustic echo wave reflections | Soft fabrics & sound absorbing foam | 10 to 25 milliseconds echo wait | Moderate: open acoustic ports |
The comparative data illustrates why full-body electronic skin is necessary for humanoid safety. Optical cameras provide excellent guidance when a robot approaches a table, but once the robot hand closes around an object, the cameras cannot see what is happening beneath the fingers. Joint torque sensors can detect when a robot arm hits a brick wall, but lack the sensitivity to detect when a delicate ceramic plate begins to slide out of a mechanical grasp. MoSkin supplies high-resolution tactile telemetry, allowing the machine to measure normal pressure, shear friction, and micro-vibrations in real time. Robot coordination software systems were detailed in our review of Destro AI coordinating automation systems.
MoTact Algorithms and the MoWorld Foundation Model
Capturing raw sensory signals from hundreds of thousands of electronic skin nodes creates an immense computing challenge. If every sensor sends data simultaneously, the incoming data stream can overwhelm the robot onboard computing processors.
MoSense developed MoTact, a specialized signal processing engine that filters and compresses tactile data at the edge. The software mimics the human peripheral nervous system: discarding redundant background signals when pressure is steady, and prioritizing high-speed alerts when shear friction indicates an object is slipping. Beyond signal processing, MoSense is training MoWorld: a multimodal foundation model that uses tactile telemetry to improve robot motion control. By training neural networks on synchronized streams of video pixels and tactile force vectors, MoWorld teaches robots physical intuition. A robot powered by MoWorld can predict how much force is required to peel an orange, open a stiff refrigerator door, or support an elderly human standing up from a chair without causing injury. Multimodal robot training models were analyzed in our report detailing how Skild AI and Nvidia trained physical automation tools.
The Shanghai Robotics Industrial Cluster
The rapid ascent of MoSense connects directly to Shanghai established hardware supply networks. The company is headquartered in Shanghai, with deep research ties to the Hong Kong University of Science and Technology.
Shanghai has emerged as a premier global manufacturing cluster for embodied intelligence. Within a fifty-mile radius, MoSense can collaborate directly with commercial humanoid robot builders like Agibot and LimX Dynamics, semiconductor foundries, and 3D printing equipment suppliers. When MoSense designs a new electronic skin prototype for a specific robot forearm, local manufacturing partners can produce test components within forty-eight hours. This rapid prototyping loop gives Chinese robotics ventures significant engineering velocity compared to Western startups that must wait weeks for overseas component shipments. The inclusion of commercial robotics makers LimX Dynamics and Agibot in the funding syndicate guarantees MoSense immediate commercial deployment channels, ensuring that its electronic skin is tested on real humanoid platforms rolling off assembly lines. Commercial robotics developments were explored in our analysis of nursing room hardware automation.
The Future Outlook for Physical Robot Touch
MoSense RMB 100M Angel-plus financing proves that the robotics industry has recognized the limits of pure computer vision. The romantic phase of humanoid robotics: showing machines executing pre-programmed dance routines on stage: has run its course. For humanoid robots to become useful domestic helpers and industrial workers, they must master the physical mechanics of touch.
By using magneto-photocuring 3D printing to embed tactile sensors directly into structural components, Yan Zhaoxu and his team solved the mechanical durability flaw that kept electronic skins trapped in academic research labs. As MoSense scales production and refines its MoWorld motion models, the company is supplying the physical sensory feedback needed to make robots truly safe around human beings. In the emerging era of embodied machine intelligence, the robots that change the world will not only be those that see and hear, but those that can reach out, feel the world with care, and touch the physical future with human-like grace.
Read More on TechRobust:
Umar Abubakar
 LinkedIn
Umar Abubakar
Expertise:Editorial Leadership, Product Design (UI/UX), Digital Media Strategy, Technology Systems, Product Architecture
Award:TechRobust Visionary Leader of the Year 2025
Umar serves as Editor-In-Chief of TechRobust, combining editorial vision with senior product design expertise to shape how modern technology stories are built, packaged, and told. Overseeing all editorial verticals, he directs coverage across global and regional tech industry while applying deep design thinking to publication strategy and reader experience.